로봇 팔용 서보 평행 그리퍼
MG90S 서보 하나로 움직이는 작은 로봇 팔 그리퍼예요. 서보가 20잇 기어를 돌리고, 그 기어가 똑같은 기어를 반대로 돌려서 두 조가 함께 열리고 닫혀요. 각 손가락은 길이가 같은 두 링크(평행사변형)에 매달려 있어서, 호를 그리며 흔들리지 않고 전체 스트로크 동안 패드가 서로 평행하게 유지돼요. Grip 애니메이션에서는 기어가 맞물려 구르고 손가락이 열렸다가 물체를 잡고 다시 열려요. 검사에서는 이가 올바른 간격으로 맞물리는지, 조가 설정한 크기까지 열리고 닿지 않은 채 8mm까지 닫히는지, 서보의 2.0kg cm가 30mm 큐브에서 조 하나당 약 3N을 내는지, TPU 패드가 작은 나무 블록을 여유 있게 잡는지 보여 줘요.
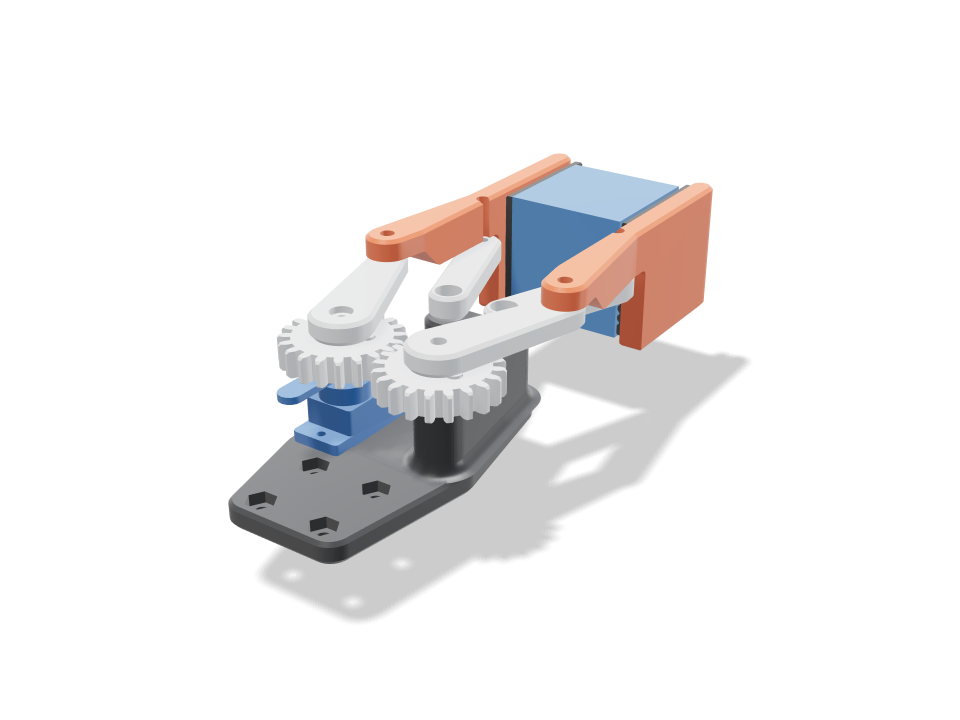
Ask for the sizes you want to tweak, e.g. “make the width adjustable”.
기본 크기 사양
Bambu Lab A1에서 pla / TPU로 실제 빌드해 측정했어요. 위 슬라이더를 움직이면 모든 숫자가 실시간으로 바뀌어요.
- 전체 크기
- 57 × 139 × 38 mm
- 부품 수
- 11
- 필라멘트
- 38 g
- 출력 시간
- 1 h 52 min
- 빌드 플레이트
- 1
- 서포트
- 필요 없음
공학 검사
검사 이름과 파라미터 이름은 CAD 엔진에서 그대로 나오기 때문에 영어로 표시돼요.
- Gears mesh in phasecentre distance m(z1+z2)/2 = 25.00 mm, 20/20 teeth, module 1.25; overlap 0.000 / 0.000 mm3 at rest / turned 17 deg; contact ratio 1.45; backlash 0.21 mm at the pitch circle (0.1 mm flank gap each side)
- No tooth undercut20 teeth at 1:1 (20 deg) vs 13 minimum
- Teeth take the servo's stall torque3.2 MPa at the tooth root (Lewis, Y 0.322) for half of 0.196 N m through the mesh; PLA allows 16.7 (teeth printed flat, along the layers)
- Jaws stay parallel (four-bar closes)frame pivots and finger pins both 31.4 mm apart, arm and idler both 31.7 mm: a parallelogram, so the finger only translates; idler end meets the finger pin within 0.0e+0 mm at 0/20/30/55 deg
- Jaw rangeopens to 60 mm at 55 deg, closes to 8 mm at 0 deg with the fingers clear of each other and the frame (overlap 0.00 mm3); 55 deg of servo travel
- Object fits between the open jaws15.0 mm each side round the 30 mm cube when open; the jaws meet it at 20.3 deg
- Pads close square on the objectclosed pads touch the cube at x = +-15 mm (overlap 0.00 mm3), 29 mm of pad along it; links and frame clear; open, nothing touches it (0.00 mm3)
- Grip holds the object3.3 N per jaw at stall (2.0 kg cm through 31.7 mm links at 20 deg); friction 3.3 N vs 0.56 N to hold a 19 g wooden cube at 3 g (a quick lift)
- Pivot pinsM3 screws as pins: finger loads 10.7 N (arm) and 11.4 N (idler); bore pressure 0.76 MPa (keep under ~5 in PLA), screw shear 1.6 MPa
- Arm root bending0.6 MPa at the 14 x 5 mm hub for 0.098 N m vs 16.7 along the layers
- Jaw root bending2.9 MPa at the jaw root (grip x3 for a bump) vs 16.7
- Horn screw drives the gearstall torque on the M2 horn screw 7.5 mm out: 26 N, 3.1 MPa bearing in the gear vs 16.7; the stock horn screw on the spline centres it
- Servo seated and screwedMG90S tabs rest on the plate, 2x M2 self-tappers 27.8 mm apart; body passes a window 0.3 mm clear (overlap 0.00 mm3)
- Pad retaineddovetail 2 mm deep, 1.0 mm undercut each side carries the object's weight; slides in from the tip against a closed back end
- MG90S servo goes in23 poses along its path clear of every part.
- 30 mm cube goes in40 poses along its path clear of every part.
- driver: finger pin goes in20 poses along its path clear of every part.
- driver: arm pin goes in20 poses along its path clear of every part.
- driver: gear-right axle goes in20 poses along its path clear of every part.
조절 가능한 치수
| 설정 | 기본값 | 범위 |
|---|---|---|
| Max jaw opening | 60 mm | 40–80 mm |
| Finger length | 36 mm | 24–56 mm |
| Object size | 30 mm | 15–50 mm |
| Held object | cube | — |
| Pivot screws | M3 | — |
부품 목록
| 부품 | 수량 | 크기(mm) | 필라멘트 | 시간 |
|---|---|---|---|---|
| base | 1 | 42 × 77 × 21 | 11 g | 21 min |
| gear-left | 1 | 27 × 27 × 6 | 2 g | 7 min |
| gear-right | 1 | 27 × 27 × 6 | 2 g | 7 min |
| arm-left | 1 | 23 × 41 × 8 | 2 g | 7 min |
| arm-right | 1 | 23 × 41 × 8 | 2 g | 7 min |
| idler-left | 1 | 20 × 39 × 6 | 1 g | 6 min |
| idler-right | 1 | 20 × 39 × 6 | 1 g | 6 min |
| finger-left | 1 | 11 × 77 × 32 | 6 g | 14 min |
| finger-right | 1 | 11 × 77 × 32 | 6 g | 14 min |
| pad-left | 1 | 4 × 29 × 33 | 3 g | 11 min |
| pad-right | 1 | 4 × 29 × 33 | 3 g | 11 min |
만드는 법
- 집고 싶은 물건에 맞춰 최대 조 벌림과 물체 크기를 설정한 다음, 손가락 길이를 고르세요.
- 베이스, 기어, 암, 아이들러는 PLA로 눕혀서, 손가락은 윗면을 아래로, 패드 두 개는 TPU로 출력하세요.
- MG90S를 베이스에 넣고 탭을 나사로 고정한 뒤, 혼을 왼쪽 기어 아래에 나사로 고정하고 스플라인에 눌러 끼우세요. 이어서 기어, 암, 아이들러, 손가락을 피벗 나사로 조립하세요.
- 패드를 끝에서부터 손가락 홈에 밀어 넣고, 서보를 중앙에 맞춘 다음, M3 구멍 네 개로 베이스를 팔에 고정하세요.
출력 팁
- 기어와 링크는 벽 3개로 눕혀서 출력하세요. 암을 달기 전에 두 기어가 함께 부드럽게 도는지 확인하세요.
- 패드는 TPU 95A로 뒤쪽 끝을 세워서 출력하면 도브테일과 리브가 깔끔하게 나와요.
- 피벗 나사는 살짝 조이기만 하고 꽉 조이지 마세요. 링크가 자기 무게로 흔들릴 정도여야 해요.
자주 묻는 질문
MG90S 대신 SG90도 되나요?
이대로는 안 돼요. SG90은 키가 더 작아서 혼이 기어보다 아래에 놓여요. 플레이트, 창, 기어 높이는 MG90S에 맞춰져 있고, 잡는 힘 수치도 그 토크로 계산했어요.
얼마나 무거운 물건을 잡을 수 있나요?
스톨 상태에서 30mm 큐브에 조 하나당 약 3N으로 집어요. TPU 패드로 나무 블록이나 출력한 테스트 큐브 같은 작고 가벼운 부품을 잡아요. 무거운 공구용은 아니에요.
나사가 필요한가요?
네. M3 나사(슬라이더로 M2.5 / M4도 가능)가 피벗 핀 역할을 하고, M2 나사 두 개가 서보를 잡고, M3 나사와 너트 네 세트로 팔에 고정해요.
카탈로그에 없는 모양이 필요하세요? 텍스트 CAD 변환으로 직접 말로 설명해 보세요
Comments