NEMA17 planet dişli kutusu
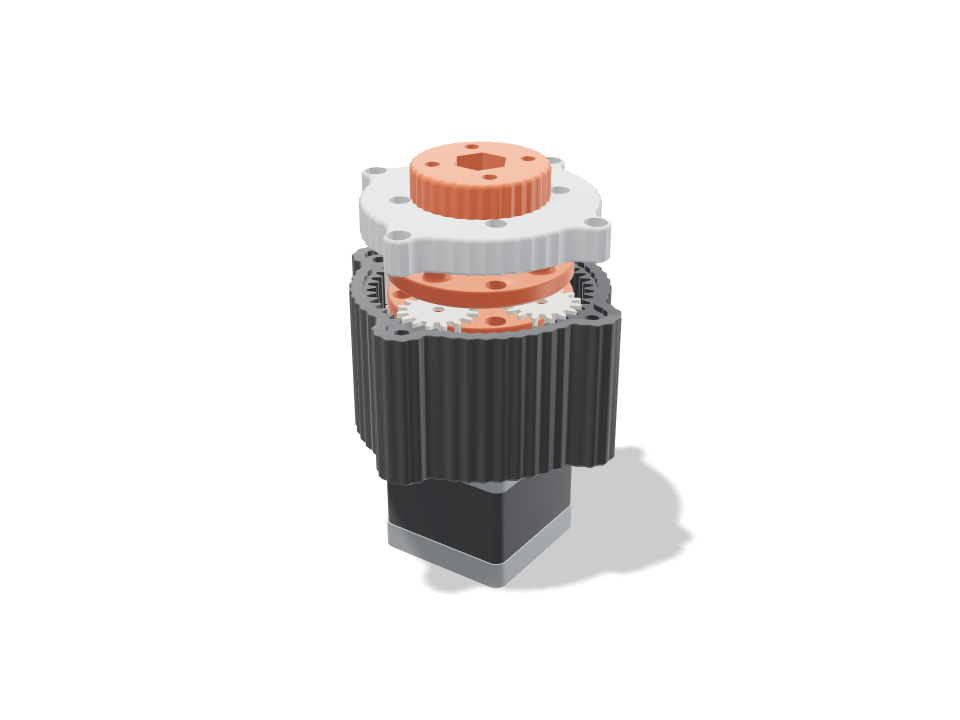
Doğrudan bir NEMA17 step motora vidalanan iki kademeli bir planet dişli kutusu. İlk güneş motorun D milini geçer, her kademede dört planet oluklu gövdeye kesilmiş tek ortak halkanın etrafında yuvarlanır, ilk taşıyıcı ikinci güneşi taşır ve ikinci taşıyıcı, kapaktaki 608 rulmanda dönen bir M8 cıvatayla çıkış flanşını çevirir. Oynat'a bas: mil güneşi döndürürken planetler hem yörüngede döner hem kendi etrafında döner ve her taşıyıcı gerçek düşürülmüş hızında döner. Kontroller, dişlilerin dururken ve örneklenen her konumda serbest olduğunu, planetlerin eşit aralıklı ve fazda olduğunu, dişlerin (Lewis diş dibi gerilmesi) ve 3 mm çelik pimlerin motorun 0,4 N m durma torkunu 16:1 düşürme boyunca taşıdığını (çıkışta yaklaşık 5,4 N m) ve her parçanın açık bir giriş yolu olduğunu kanıtlar. Bu bir kittir: basılan parçalar artı pimler, bir rulman ve birkaç vida.
Ask for the sizes you want to tweak, e.g. “make the width adjustable”.
Varsayılan boyutta özellikler
Bambu Lab A1 üzerinde pla ile gerçek yapıdan ölçüldü. Yukarıdaki bir kaydırıcıyı sürüklediğinde her sayı anında güncellenir.
- Toplam boyut
- 88 × 88 × 67 mm
- Parça
- 14
- Filament
- 100 g
- Baskı süresi
- 3 h 23 min
- Baskı plakası
- 1
- Destek
- Gerekmez
Mühendislik kontrolleri
Kontrol ve parametre adları doğrudan CAD motorundan gelir ve İngilizce gösterilir.
- Every part stands free at resttotal overlap 0.000 mm³ between gears, carriers, housing and cap with a 0.15 mm flank gap and 0.4 mm axial gaps
- Planets space evenly(16 + 48) / 4 = 16, a whole number, so all four planets mesh in phase
- Planets clear each other5.8 mm between neighbouring planet tips
- No tooth undercutsun/planet 1.00:1 needs 13+ teeth at 20 deg; smallest here 16
- Teeth overlap in meshcontact ratio 1.35 sun-planet, 1.51 planet-ring after the flank gaps (1.2+ runs smoothly)
- Stage 1 teeth take the stall torque5.0 MPa at the tooth root (Lewis, Y 0.296, 8 mm face) with 0.40 N m on its sun shared by 3 of 4 planets; PLA allows 16.7 along the layers
- Stage 1 planet pins hold27 N per pin: 44 MPa bending in the 3 mm hardened dowel (allow 500), 1.1 MPa in the planet bore (keep under ~6), 11.2 MPa in the 5 mm carrier socket vs 16.7
- Stage 2 teeth take the stall torque13.6 MPa at the tooth root (Lewis, Y 0.296, 10 mm face) with 1.47 N m on its sun shared by 3 of 4 planets; PLA allows 16.7 along the layers
- Stage 2 planet pins hold98 N per pin: 200 MPa bending in the 3 mm hardened dowel (allow 500), 3.3 MPa in the planet bore (keep under ~6), 13.9 MPa in the 10 mm carrier socket vs 16.7
- Sun grips the D-shaft6.9 MPa on 9.7 mm of the shaft flat at 0.4 N m vs 16.7; the bore prints ~0.1 mm small for a press fit
- Motor shaft clears all but its sunshaft tip at 24 mm runs in carrier 1's bushing; overlap 0.00 mm³, sun bore 0.01
- Housing bolts to the motorseats on the 22 mm boss; M3x8 bites 4.5 mm into the motor's threads; 62 N per screw from the 5.4 N m reaction, 5.2 MPa on the floor vs 16.7
- Output bolt carries the torque5.4 N m out: 102 MPa shear in the M8 core (8.8 bolt, allow 190); hex pockets 7.0 / 4.6 MPa vs 16.7
- 608 is seated and capturedflush in a 7 mm pocket on a 3.00 mm lip under the outer race; the inner race is clamped between 8 x 12 mm speed rings by the carrier shoulder and the flange, which runs 1.0 mm clear of the cap; overlap -0.00 mm³
- Cap centres on the housingthe cap sits 1.5 mm deep in the housing's bezel with 0.15 mm all round, so the bearing lands on the ring's axis; flat on the ring top; M3x12 into heat-set inserts in the lobes, 1.2 mm of cap round each screw head
- Ring wall4.2 mm under the flutes, 2.3 mm between each insert and the ring's tooth roots, 3.4 mm bezel rim standing outside the tooth roots
- Bolt and nut fitM8 x 30: the nyloc sits 5.9 mm above the flange underside, its top flush with the bolt end; the carrier shoulder passes the 8 mm lip hole with 0.5 mm all round
- Ratio16.00:1 (2 x 4.00, 16/16/48 teeth, module 1.25): 4.0 motor turns = 0.25 output turns; about 5.4 N m out from 0.4 N m at 92% per stage
- NEMA17 stepper goes in23 poses along its path clear of every part.
- NEMA17 end caps goes in23 poses along its path clear of every part.
- 608 bearing (in the cap) goes in6 poses along its path clear of every part.
- 2x M8 speed ring 8 x 12 x 1 goes in15 poses along its path clear of every part.
- M8 x 30 hex bolt goes in13 poses along its path clear of every part.
- M8 nyloc nut (in the flange) goes in15 poses along its path clear of every part.
- 3 mm steel pins, stage 1 goes in10 poses along its path clear of every part.
- 3 mm steel pins, stage 2 goes in10 poses along its path clear of every part.
- 4x M3x8 into the motor goes in15 poses along its path clear of every part.
- 4x M3x12 cap screws goes in15 poses along its path clear of every part.
- driver: motor screws (through the tool holes) goes in20 poses along its path clear of every part.
- driver: cap screws goes in20 poses along its path clear of every part.
Ayarlanabilir ölçüler
| Ayar | Varsayılan | Aralık |
|---|---|---|
| Tooth size (module) | 1.25 mm | 1.25–1.75 mm |
| Sun teeth | 16 | 14–20 |
| Planet teeth | 16 | 14–22 |
| Stages | 2 | 1–2 |
| Gear gap (each flank) | 0.15 mm | 0.1–0.25 mm |
Parça listesi
| Parça | Adet | Boyut (mm) | Filament | Süre |
|---|---|---|---|---|
| housing | 1 | 88 × 88 × 44 | 45 g | 1 h 6 min |
| sun 1 | 1 | 22 × 22 × 13 | 2 g | 8 min |
| planet 1-1 | 1 | 22 × 22 × 8 | 2 g | 7 min |
| planet 1-2 | 1 | 22 × 22 × 8 | 2 g | 7 min |
| planet 1-3 | 1 | 22 × 22 × 8 | 2 g | 7 min |
| planet 1-4 | 1 | 22 × 22 × 8 | 2 g | 7 min |
| planet 2-1 | 1 | 22 × 22 × 10 | 2 g | 8 min |
| planet 2-2 | 1 | 22 × 22 × 10 | 2 g | 8 min |
| planet 2-3 | 1 | 22 × 22 × 10 | 2 g | 8 min |
| planet 2-4 | 1 | 22 × 22 × 10 | 2 g | 8 min |
| carrier 1 | 1 | 52 × 52 × 15 | 8 g | 16 min |
| output carrier | 1 | 52 × 52 × 13 | 8 g | 15 min |
| cap | 1 | 80 × 80 × 10 | 15 g | 24 min |
| output flange | 1 | 38 × 38 × 14 | 7 g | 14 min |
Nasıl yapılır
- Diş boyutunu, güneş ve planet diş sayılarını ve bir ya da iki kademeyi seç; oran ve çıkış torku kontrollerde güncellenir.
- Gövdeyi, taşıyıcıları ve planetleri düz yüzü aşağıda, güneşi dişleri aşağıda, kapağı ve flanşı da düz yüzü aşağıda bas. Destek yok.
- M3 ısıl ekleri gövde kulaklarına bastır, gövdeyi 4x M3x8 ile motora vidala, güneşi mile geçir, sonra planetleri kademe kademe preslenmiş 3 mm pimlerinin üzerine yerleştir.
- M8 cıvatayı çıkış taşıyıcısından yukarı it, bir ara pulu ekle, kapağı 608 yuvasında olacak şekilde indir, vidala, sonra flanşı naylon kilitli somunuyla cıvataya vidala.
Baskı ipuçları
- Gösterilen kontroller için PLA yeterlidir; PETG ya da PA-CF dişliler sürekli yük altında daha uzun ömürlüdür. Dişler dolu olsun diye dişlileri 3-4 duvarla bas.
- Dişliler sıkışıyorsa dişli boşluğunu 0,02 mm artır; takırdıyorsa azalt. Pimlere bir damla kuru PTFE yağlayıcı yardımcı olur.
- Pim kontrolü sertleştirilmiş 3 mm silindirik pimleri (ISO 8734) varsayar; kesilmiş çiviler ya da yumuşak çubuk eğilir.
Sık sorulan sorular
Hangi donanım gerekiyor?
Bir NEMA17 step motor, 3 mm çelik silindirik pimler (kademe başına dört), bir 608 rulman, iki adet 8 x 12 x 1 mm ara pulu, bir M8 altıgen cıvata ve naylon kilitli somun, 4x M3x8 ve 4x M3x12 vida ve kapak ile çıkış flanşı için 4 + 4 M3 ısıl ek.
Gerçekte ne kadar tork veriyor?
Varsayılan 16:1 ve 0,4 N m'lik bir motorla, basılı kademe başına %92 varsayılarak flanşta tahmin yaklaşık 5,4 N m'dir. Bu bir hesap, ölçüm değil; ağır bir şey asmadan önce tezgâhta test et.
Tek kademeli bir sürüm yapabilir miyim?
Evet. Aynı flanş ve rulmanla daha kısa bir 4:1 kutu için kademeleri 1 yap. Bu durumda hareket temiz bir döngü olarak çalışır, çünkü her parça dört motor turundan sonra başladığı yere döner.
Katalogda olmayan bir şekle mi ihtiyacın var? Metinden CAD ile kendi kelimelerinle tarif et
Comments